


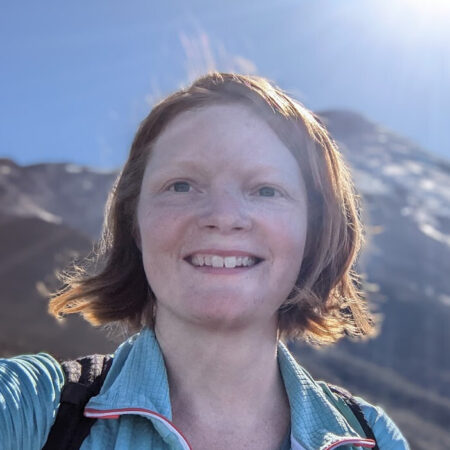
Dr.
Helen
Oleynikova
Helen Oleynikova completed her PhD in the Autonomous Systems Lab at ETH Zurich researching autonomous mapping and planning for collision avoidance on drones. She has additionally worked at Microsoft Mixed Reality and AI Lab in Zurich on the intersection of Mixed Reality and Robotics, and later at Nvidia in Zurich on GPU-accelerated 3D mapping for mobile robots. As a Senior Researcher at the ASL she developed robot perception, 3D mapping, and mobile manipulation for a variety of applications, which she will now apply at Exclaim Robotics.
Role in the NCCR Digital Fabrication
Current position
CEO & Founder - Exclaim RoboticsNCCR publications
-
nvblox: GPU-Accelerated Incremental Signed Distance Field Mapping (2024)
- Date: 01.01.2024
- Authors: Alexander Millane, Dr. Helen Oleynikova, Emilie Wirbel, Remo Steiner, Vikram Ramasamy, David Tingdahl, Prof. Dr. Roland Siegwart
- Event: 41st IEEE International Conference on Robotics and Automation (ICRA 2024)
-
COIN-LIO: Complementary Intensity-Augmented LiDAR Inertial Odometry (2024)
- Date: 01.01.2024
- Authors: Patrick Pfreundschuh, Dr. Helen Oleynikova, Cesar Cadena, Prof. Dr. Roland Siegwart, Olov Andersson
- Event: 41st IEEE International Conference on Robotics and Automation (ICRA 2024)